ADV 自主配送机器人ADV · Autonomous Delivery Robot
在配送机器人团队中,参与 Jetson–STM32 串口通信、编码器反馈与 PID 电机控制联调,结合传感接口和 SolidWorks 机械资料协调上位计算、底层执行及结构安装。Worked within a delivery-robot team on Jetson–STM32 UART communication, encoder feedback and PID motor-control integration, using sensor interfaces and SolidWorks materials to coordinate computing, actuation and mounting.
- 01输入Input机器人传感器Robot Sensors
- LiDAR / RGB-DLiDAR / RGB-D
- UARTUART02上位计算HostJetson 上位机Jetson Host
- 感知与任务层计算Perception and task-level computing
- 03底层控制ControlSTM32 控制STM32 Control
- 编码器反馈 · PIDEncoder feedback · PID
- 04执行Actuation电机输出Motors
- 运动响应与执行机构Motion response and actuators
项目背景Project Overview
配送机器人连接环境感知、上位计算、串口通信、底盘控制与机械结构。团队方案由 Jetson 承担上位计算,STM32 处理底层传感和运动控制;我的工作集中在通信及控制接口联调。The delivery robot connects sensing, high-level computing, UART communication, chassis control and mechanical design. The team architecture assigns computing to Jetson and low-level sensing and motion control to STM32; my work focused on communication and control-interface integration.
技术目标Engineering Objective
让上层指令与底层运动之间建立可调试的数据通路,并把编码器反馈、电机输出和传感接口放到同一系统中检查。机械安装、电气连接和程序行为需要在团队集成中协调。Create a debuggable path from high-level commands to low-level motion, integrating encoder feedback, motor output and sensor interfaces. Mechanical mounting, electrical connections and firmware behavior must be coordinated across the team.
系统架构System Architecture
- 01感知与上层计算:LiDAR、RGB-D 和 Jetson。Sensing and high-level computing: LiDAR, RGB-D and Jetson.
- 02通信:Jetson 与 STM32 通过 UART 交换指令和反馈;STM32 端 DMA 收发机制以对应固件配置为准。Communication: Jetson and STM32 exchange commands and feedback over UART; MCU-side DMA transfer behavior depends on the corresponding firmware configuration.
- 03底层执行:STM32、编码器反馈、PID 和电机驱动。Low-level execution: STM32, encoder feedback, PID and motor drivers.
- 04结构与供电:机械装配、现有 DC/DC 模块与系统接口。Structure and power: mechanical assembly, existing DC/DC modules and system interfaces.
关键技术实现Technical Implementation
计算与控制分工Compute/control responsibilities
将感知和任务层留在 Jetson,传感读取、反馈处理与电机控制放在 STM32。联调沿着上位指令、通信数据、控制器反馈和执行响应分段展开。Jetson hosts perception and task-level computing; STM32 handles sensing, feedback and motor control. Integration follows high-level commands, communication data, controller feedback and actuator response.
UART 通信与编码器反馈UART communication and encoder feedback
参与 Jetson 上位机与 STM32 控制器之间的串口通信联调,并结合 MCU 端的数据收发、编码器反馈和电机控制检查指令执行过程。STM32 端 DMA 的具体配置以对应固件为准。Worked on UART communication between the Jetson host and STM32 controller, examining command transfer alongside encoder feedback and motor response. MCU-side DMA configuration is described according to the corresponding firmware.
机电与供电集成Mechatronics and power integration
结合 SolidWorks 机械资料和现有供电方案,梳理结构安装、电气连接与控制器接口。Webots 仿真工作和 DC/DC 模块测试按独立项目记录说明,不与已验证的整车结果混为一谈。Used SolidWorks mechanical materials and the existing power-system design to review mounting, electrical connections, and controller interfaces. Webots simulation and DC/DC testing are treated as separate work items rather than verified full-vehicle results.
整车 CAD 与装配结构Robot CAD & Assembly
配送车模型按车身外壳、轮组支撑、底盘连接与内部货舱分层组织。原始资料保留 SolidWorks 总装和零件、整车 STEP,以及组件 STL;这些文件用于分析安装关系和空间分配。STL 包含重复组件实例,文件数量不等于独立设计零件数量。The delivery-vehicle model separates the body enclosure, wheel supports, chassis connections and cargo interior. The archive includes SolidWorks assemblies and parts, a full-vehicle STEP and component STLs for examining mounting and spatial layout. Repeated STL instances are not counted as independently designed parts.
整车、拆解与内部结构动画展示设计模型。模型中可见的外壳、接口预留和装配关系,不直接代表相应机构已经加工或完成动作试验。Overview, exploded and interior animations show the design model. Visible enclosures, interface provisions and assembly relationships do not establish fabrication or functional tests.
来源:配送车.SLDASM、配送车.STEP;团队 CAD 展示视频Source: delivery-vehicle SLDASM and STEP; team CAD presentation video可调底盘:两种设计构型Adjustable Chassis: Two Design Configurations
手册第 81 页并列展示宽轮距低底盘与窄轮距高底盘。阅读重点是轮组相对车身的位置、底部空间和连接机构的几何关系;两幅图是设计状态,而非行驶前后对比或实车通过性测试。Page 81 compares wide-track/low-chassis and narrow-track/high-chassis configurations. The useful comparison is wheel position relative to the body, underbody space and linkage geometry. These are design states, not before-and-after driving tests.
结构与控制的接口可按轮组安装、连杆活动空间、传感器视野和线束余量检查。改变构型后,轮组几何与坐标关系需要重新核对;目前不为这套模型填写未经测试的载重、速度、离地间隙或稳定性提升指标。Mechanical/control interfaces can be reviewed through wheel mounting, linkage clearance, sensor field of view and harness allowance. Geometry and coordinate relationships need checking when configuration changes. No untested payload, speed, clearance or stability improvement is assigned to this model.
来源:团队技术手册第 73、81 页;图 85–86Source: team design manual pp. 73 and 81; Figs. 85–86货舱与装配接口Cargo Compartment & Assembly Interfaces
手册第 71–72 页给出货舱空间与机械布置,第 73 页连接到底盘结构。结合拆解和内部结构动画,可以讨论舱体、出货门、支撑件与执行机构的相对位置,以及装配和维护的可达空间。Pages 71–72 describe cargo space and mechanism layout, followed by chassis structure on page 73. Exploded and interior animations support discussion of the enclosure, delivery door, supports, actuator positioning and access for assembly or maintenance.
升降、旋转分拣和出货属于团队机构构想。本页不把 CAD 动画当作自动分拣或实际配送演示;相关行程、碰撞检查及机构驱动参数需要匹配的工程与测试记录。Lifting, rotary sorting and delivery are team mechanism concepts. CAD animation is not presented as automatic sorting or physical delivery. Travel, collision checks and actuator parameters require matching engineering and test records.
来源:团队手册第 71–73 页;CAD 视频 02:18–02:44、03:45–04:13Source: manual pp. 71–73; CAD video 02:18–02:44 and 03:45–04:13通信、控制与调试边界Communication, Control & Debugging Scope
既有个人工作保留 Jetson–STM32 UART、编码器反馈和 PID 电机控制接口联调。系统按“上层指令 → 串口接收 → 底层控制 → 驱动输出 → 编码器反馈”分段描述;手册第 19–21 页出现 Nano、AGX Orin 与 STM32F407 的不同配置,不能合并成同一台最终装机清单。My established contribution remains Jetson–STM32 UART, encoder feedback and PID motor-interface integration. The system is described as host command → serial receive → low-level control → drive output → encoder feedback. The Nano, AGX Orin and STM32F407 variants on pages 19–21 are not merged into one final installed BOM.
本次检索的原始归档没有匹配的 C/C++、头文件或 STM32 配置工程,因此不新增 UART 帧字段、DMA 模式、中断周期及 PID 增益。可复核的下一步是对齐主机发送、MCU 接收、目标值、编码器符号和执行输出的时间记录;这是一项验证方案,不是新增测试结果。No matching C/C++ source, headers or STM32 configuration project was found in the inspected archive. No UART packet fields, DMA mode, interrupt periods or PID gains are added. A reproducible next step is to align timestamps for host transmission, MCU reception, targets, encoder signs and output; this is a validation plan, not a new test result.
车辆级 Pure Pursuit、位置/速度控制与电机级速度/电流环分别保留为手册中的设计研究。点云处理、蚁群规划、无人机、AR 与温控构想不扩写为已部署的实车功能。Vehicle-level Pure Pursuit and position/speed control remain separate from motor-level speed/current-loop studies in the manual. Point-cloud processing, ant-colony planning, drone, AR and temperature-control concepts are not expanded into deployed vehicle features.
来源:既有接口联调记录;手册第 10–21、48–50 页;本轮源码目录检索Source: established integration record; manual pp. 10–21 and 48–50; source-directory inspection概念效果展示Concept Visualizations
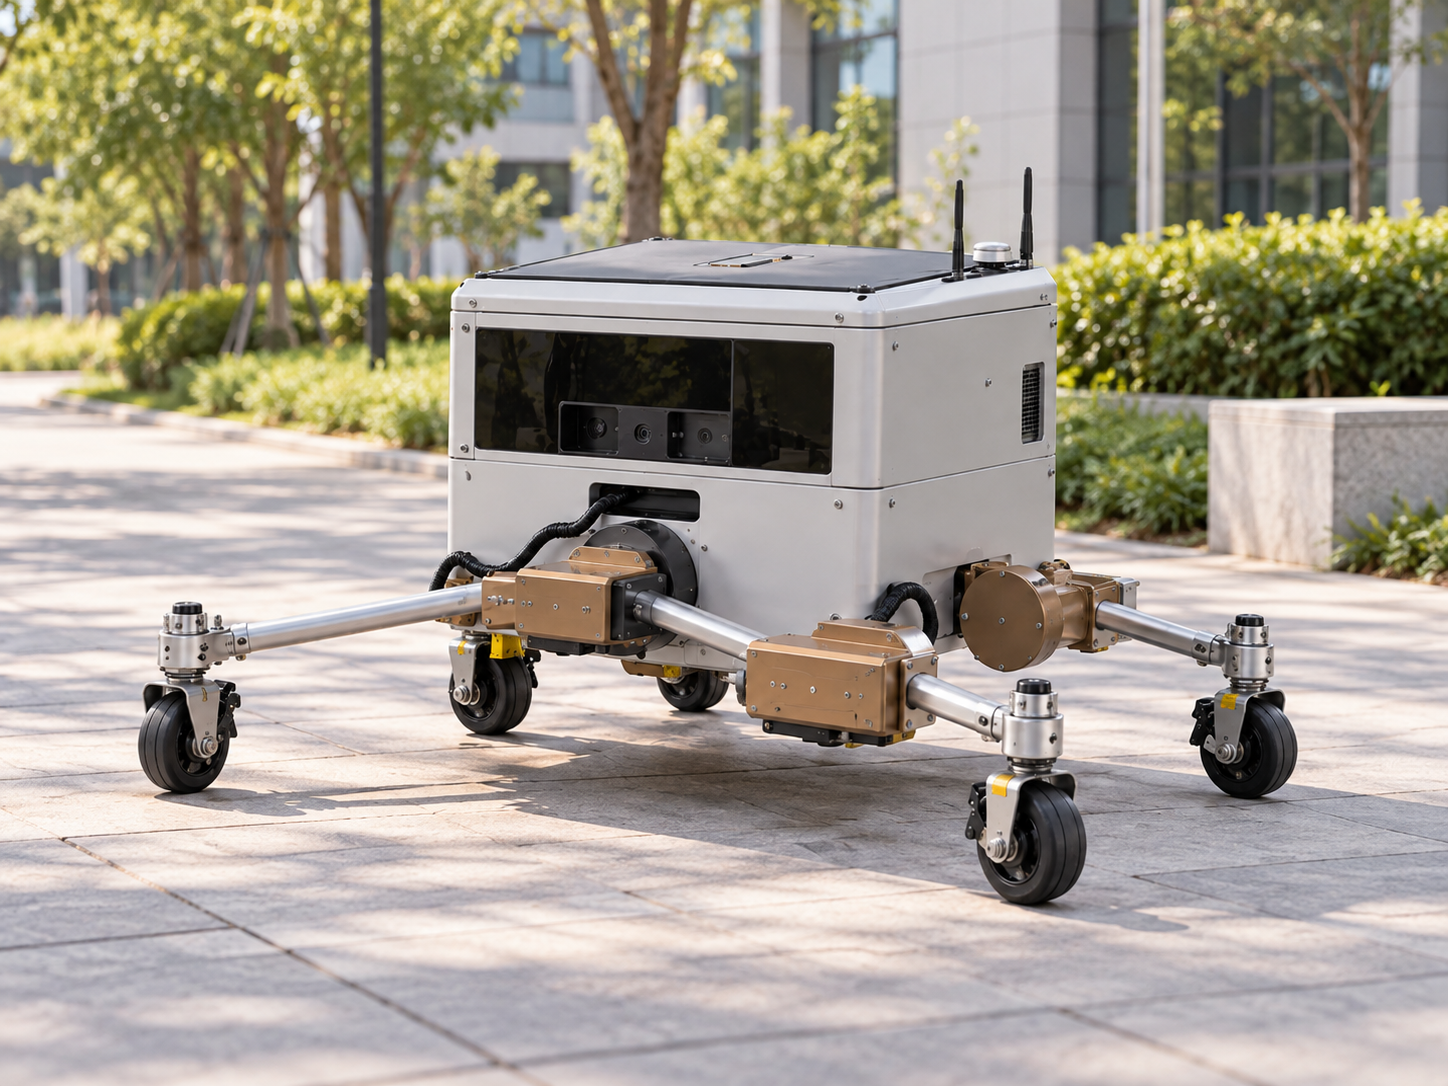
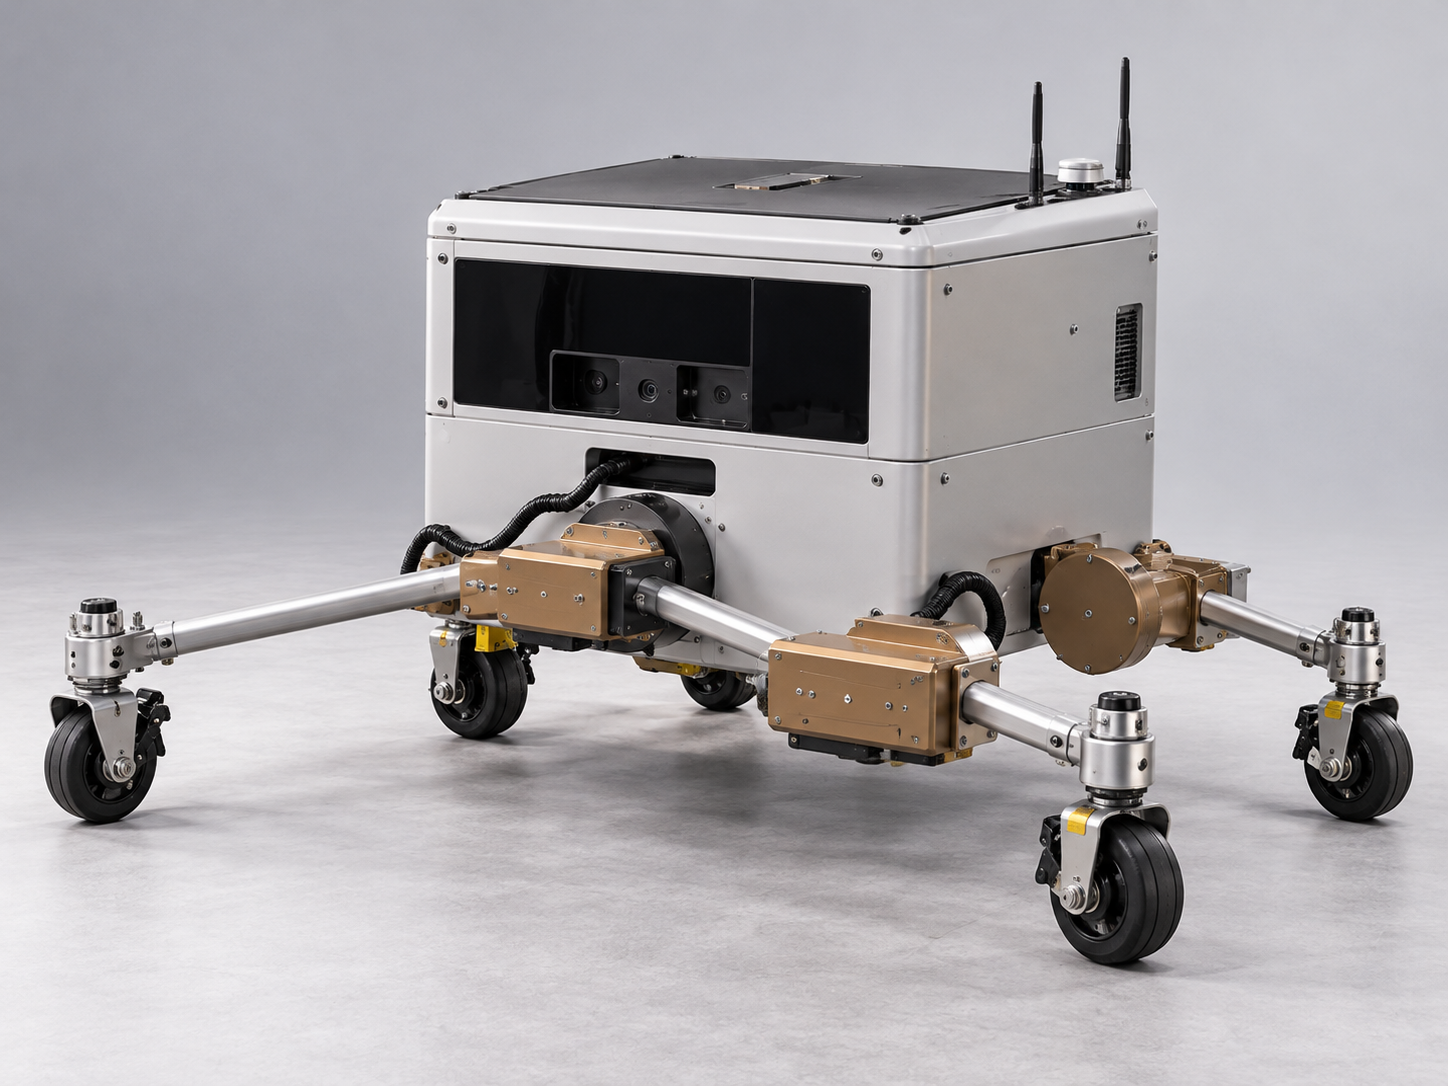
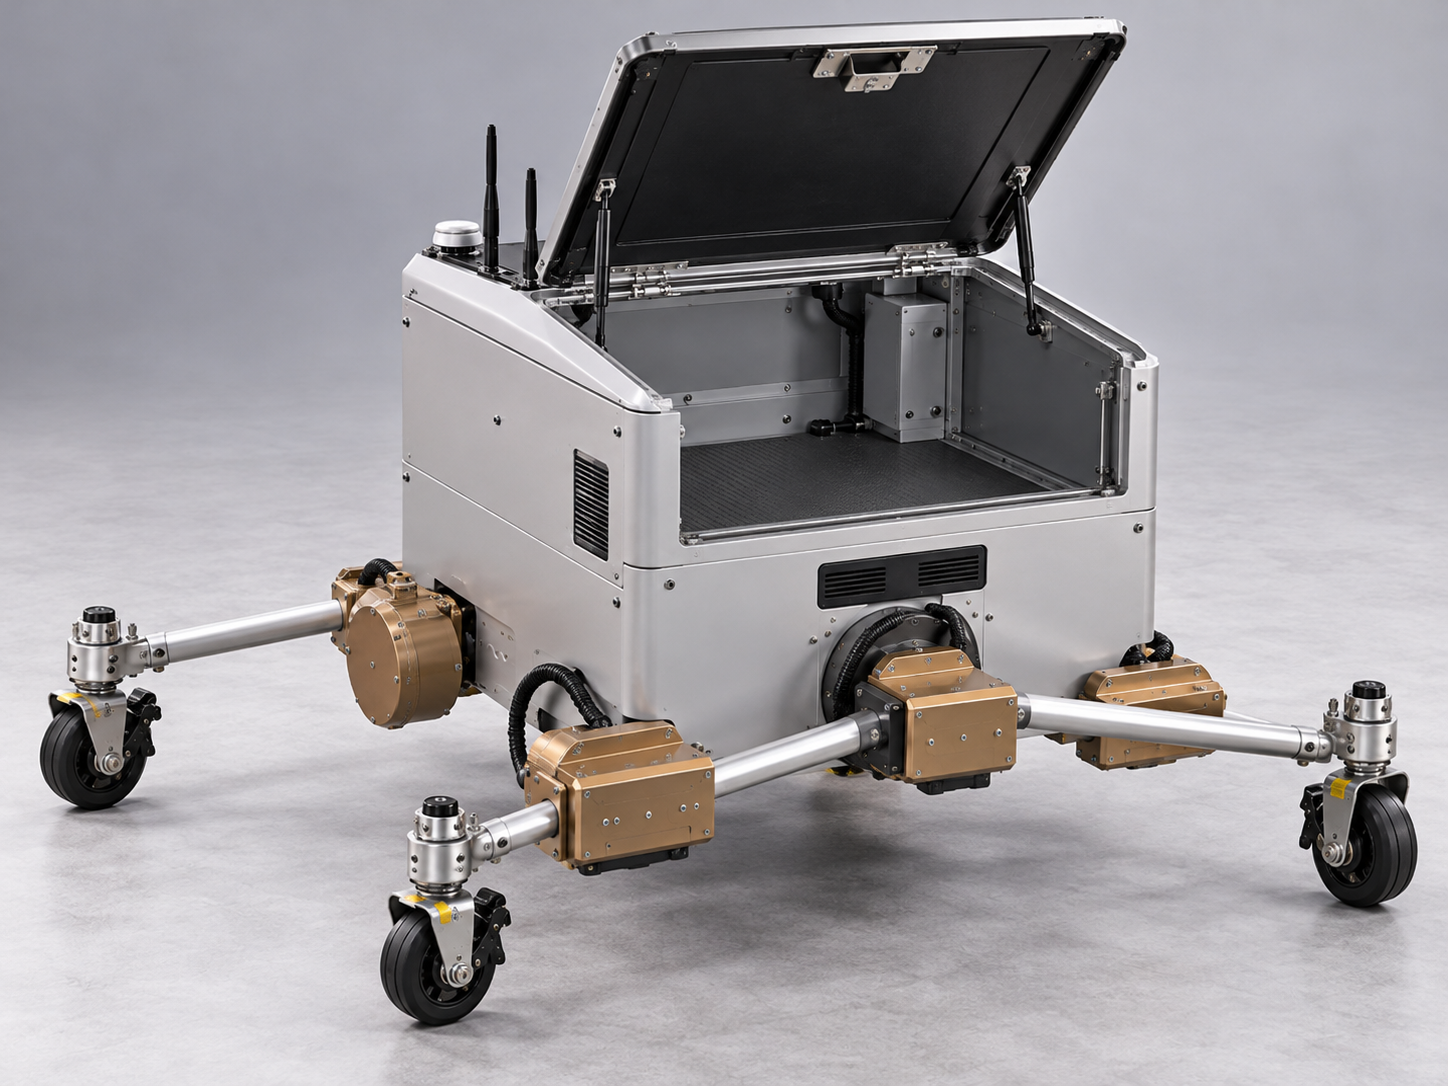
以下为用户提供的概念效果图,用于外观与场景表达。并非实物照片、原生 CAD 导出或测试记录,图中细节不作为制造或性能证据。These user-provided concept visualizations illustrate appearance and scenarios. They are not physical photographs, native CAD exports or test records, and do not establish fabrication or performance.
我的实际工作My Contributions
- 在团队中参与 Jetson–STM32 UART 通信与传感器接口联调;MCU 端 DMA 配置按对应固件说明。Worked within the team on Jetson–STM32 UART and sensor-interface integration; MCU-side DMA configuration is firmware-specific.
- 参与编码器反馈、PID 电机控制及执行机构联调。Contributed to the integration and debugging of encoder feedback, PID motor control and actuators.
- 结合 SolidWorks 结构资料、技术报告和供电方案梳理系统接口。Reviewed system interfaces using SolidWorks mechanical materials, technical reports and the power-system design.
项目成果与验证Results & Validation
技术栈Tech Stack
工程技术深入Technical Deep Dive
以 2023 室外创意设计赛团队技术手册和 CAD 装配资料为主线,分开说明获奖成果、机械/控制方案,以及已有的 UART 与运动控制接口联调经历。Use the 2023 outdoor Creative Design team manual and CAD assembly records to distinguish the verified contest output, mechanical/control proposals and established UART/motion-interface integration experience.
工程问题与模块职责Engineering question and responsibilities
如何把可调机械结构、上位计算和多层运动控制组织为可核查的系统方案,而不把方案全部写成实车验证?How can adjustable mechanics, host computing and layered motion control form a traceable system proposal without claiming that every proposal was vehicle-tested?
本页采用三层阅读:赛事实证;CAD 与团队工程方案;已有系统集成工作。个人证书确认奖项归属,不证明个人独立完成所有机械、感知或控制子系统。Read the project in three layers: verified contest output; CAD and team engineering proposals; established integration work. Personal certificates confirm award attribution, not sole authorship of all mechanical, perception or control subsystems.
不同控制层次分别阅读Read the control layers separately
车辆级纵向控制方案 · pp13–14Vehicle longitudinal proposal · pp13–14
- 01位置目标 / 反馈Position target / feedback
- 02位置环补偿Position-loop compensation
- 03速度参考 / 速度环Speed reference / speed loop
电机级驱动方案 · pp48–50Motor-drive proposal · pp48–50
- 01电机速度参考Motor-speed reference
- 02速度环 / 电流环Speed loop / current loop
- 03PWM / 换相 / 电机PWM / commutation / motor
已有接口联调范围Established interface-integration scope
- 01Jetson 上位指令Jetson host command
- 02UART → STM32UART → STM32
- 03编码器 / PID / 执行响应Encoder / PID / response
01可调底盘与货舱的机械方案Adjustable chassis and cargo-mechanism design
设计方案Design Proposal
归档包含配送车 SolidWorks 装配、39 份零件与 6 份装配体文件,以及大量 STL。手册展示可调底盘、连接/弹簧机构、出货门、升降与旋转分拣构想。CAD 文件和报告渲染可以说明结构设计存在,不能直接证明这些机构已制造或自动运行。The archive contains delivery-vehicle SolidWorks material, including 39 part files, six assemblies and numerous STLs. The manual presents an adjustable chassis, linkage/spring mechanisms, delivery doors, lifting and rotary-sorting concepts. CAD and report renders establish design material, not fabrication or automatic operation.
结构阅读可关注轮组/支架与传感器安装、舱体升降空间、连杆运动包络以及电气走线余量。这些是对现有结构资料的工程分析,不新增本人独立设计或可靠性试验经历。Engineering review can examine wheel/support and sensor mounting, lifting clearance, linkage motion envelopes and wiring allowance. These are analyses of existing design material, not new claims of sole design ownership or reliability testing.
来源:团队 CAD 装配及技术手册 pp50、71–72Source: team CAD assembly and manual pp50, 71–72
02上位机、MCU 与控制层次Host, MCU and control layers
设计方案Design Proposal
手册 pp19–21 将 Jetson 用于上位计算、STM32F407 用于传感与底盘控制;其中两块 STM32F407、AGX Orin 与 Nano 的描述存在版本冲突,因此不拼成一套最终装机清单。公开系统图保留职责层级和 Jetson/STM32 家族名称。Manual pp19–21 assigns host computing to Jetson and sensing/chassis control to STM32F407. Its descriptions of two STM32F407 boards, AGX Orin and Nano conflict across versions, so they are not combined into one final installed BOM. Public diagrams retain responsibilities and family names.
车辆级位置/速度控制、Pure Pursuit 横向跟踪,与电机级速度/电流环属于不同层次。前者产生运动参考,后者讨论驱动执行;只有找到匹配固件和测试记录,才可把手册方案写为已实现控制器。Vehicle-level position/speed control and Pure Pursuit tracking are distinct from motor-level speed/current loops. One concerns motion references and the other drive execution. Matching firmware and tests are required before describing manual proposals as implemented controllers.
来源:技术手册 pp13–21、48–50Source: manual pp13–21 and pp48–50
03感知与路线规划的方案研究Perception and route-planning design study
设计方案Design Proposal
手册 pp10–13 的障碍物流程先做车辆坐标转换和统计滤波,再按射线高度/坡度关系进行 Ray Ground Filter 地面分割,之后聚类并拟合三维包围框。这是报告方案,不把图中的点云示例当作本人机器人实测结果。The obstacle workflow in pp10–13 starts with vehicle-frame transformation and statistical filtering, then uses ray-based height/slope relations for Ray Ground Filter segmentation, followed by clustering and 3D boxes. This is a report proposal; its example point-cloud figure is not presented as a measurement from my robot.
pp17–18 的蚁群规划讨论状态转移和信息素更新,以及搜索规模与计算时间的取舍。本文不宣称已完成实际场景部署、最优路径证明或运行时性能测试。Pages 17–18 discuss ant-colony state transitions, pheromone updates and the trade-off between search scale and computation time. No deployed scenario, proof of an optimal route or runtime benchmark is claimed here.
来源:技术手册 pp10–18;方案层Source: manual pp10–18; design-study scope
04预瞄、机械机构与版本取舍Look-ahead, mechanisms and revision choices
工程分析Engineering Analysis
手册的 Pure Pursuit 分析将预瞄距离与速度关联:预瞄太短可能引起振荡,太长则影响急转弯跟踪。这里讨论设计权衡,不给出未经实车记录支撑的最佳预瞄参数。The manual relates Pure Pursuit look-ahead to speed: a short look-ahead can induce oscillation, while a long one can weaken tight-turn tracking. This is a design trade-off, not a vehicle-validated optimal parameter.
可调舱体和底盘增加机构、布线和控制状态;应检查运动包络、限位、失电状态及传感器安装基准。温控舱、AR/BIM 与无人机配送属于报告构想,不与已有 UART 联调混写成完整自动配送功能。Adjustable cargo/chassis mechanisms add mechanical, wiring and control states. Review should cover motion envelopes, limits, power-loss state and sensor mounting references. Temperature control, AR/BIM and drone delivery remain report concepts rather than completed autonomous functions inferred from UART integration.
工程分析:手册跟踪与机构方案Engineering analysis: manual tracking and mechanism proposals
05接口联调与可复现实验的下一层Interface integration and reproducible validation
工程分析Engineering Analysis
已有个人工作范围保留 Jetson–STM32 UART、编码器与 PID 电机接口联调。更细的解释应使用相同固件中的指令边界、接收状态、反馈符号和电机执行对应关系;本轮没有用报告补造 UART 数据帧或 MCU DMA 配置。Established personal scope retains Jetson–STM32 UART, encoder and PID motor-interface integration. More specific explanations require command boundaries, receive state, feedback sign and motor response from matching firmware. This review does not invent UART frames or MCU DMA settings from the report.
可进一步按主机发送→MCU 接收→执行请求→编码器反馈建立同步记录,再分别验证底盘机构和供电方案。DC/DC 纹波、负载瞬态和 Webots 仍需独立记录,不能由方案图替代。A next validation step is synchronized logging of host send, MCU receive, actuation request and encoder feedback, followed by separate mechanism and power-system tests. DC/DC ripple, load transients and Webots still require independent records.
工程分析:保留既有联调范围,未新增测试成绩Engineering analysis: existing integration scope retained; no new test result
06获奖成果、方案与本人工作Contest output, proposals and my scope
项目资料Project Records
2023 第十八届全国大学生智能汽车竞赛 · 全国总决赛智能汽车创意设计大赛二等奖;南部赛区智能汽车创意设计大赛一等奖。2023, 18th National University Students Intelligent Vehicle Competition: Second Prize in the National Final (Creative Design), and First Prize in the Southern Regional Competition (Creative Design).
两张本人证书在私人归档中核对,奖项只关联 2023 室外创意设计团队作品,不归入 2024 STC32 电磁组。证书和团队其他成员信息不公开;奖项不意味着个人独立完成报告中的全部功能。Two personal certificates were checked privately. These awards belong to the 2023 outdoor Creative Design team entry, not the 2024 STC32 electromagnetic project. Certificates and other team members’ information are not published; awards do not imply sole completion of every proposed function.
当前可讲清的是团队报告/CAD 方案和已有通信、控制接口协作。无人机、温控、AR 导航、完整感知规划链及所有机构自动运行,仍不作为已验证的整车成果。The supported presentation is the team report/CAD proposal and established communication/control-interface collaboration. Drone delivery, temperature control, AR navigation, the full perception/planning chain and automatic operation of all mechanisms are not presented as validated vehicle results.
来源:本人两张 2023 创意设计赛证书及团队手册Source: two personal 2023 Creative Design certificates and team manual
面试深入讨论Interview Deep Dive
从设计问题与已有实现出发,进一步讨论边界、观察量和验证方法。Follow the design questions and implementation details into scope, observables and validation methods.
为何区分位置/速度环与速度/电流环?Why separate position/speed and speed/current loops?
它们对应车辆运动与电机驱动两个层级,参考量、反馈和执行接口不同;不能用同一张未验证方案替代全部控制实现。They concern vehicle motion and motor drive respectively, with different references, feedback and execution interfaces. One unverified proposal cannot stand in for both implementations.
报告里的 Orin、Nano 和双 STM32 是否都装在车上?Were Orin, Nano and two STM32s all installed?
不能据现有矛盾描述作此结论;需统一版本的 BOM、固件和装机记录。页面只保留职责和家族级平台名。The conflicting descriptions do not establish that. A consistent BOM, firmware and installation record are needed; the page retains responsibilities and platform-family names.
CAD 动画能够证明什么?What can CAD animation establish?
它支持结构与装配方案的讨论,不直接证明制造、承载、机构自动运行或实车路测。It supports discussion of structure and assembly concepts, not fabrication, load capacity, automatic mechanisms or road testing.
个人奖项和个人技术分工如何关联?How do personal awards relate to technical scope?
证书证明获奖归属,个人任务仍依据既有职责和实现材料描述;团队全部子系统不因此成为个人独立成果。Certificates establish award attribution; personal tasks still follow role and implementation evidence, without turning all team subsystems into individual achievements.
工程备注 · 阶段与版本Engineering Notes · stage & revisions
- 按 2023 年展示团队项目,备选配置与实际集成分别记录。目前未核实独立的 Webots 工程和仿真结果,因此不将 Webots 列为已确认的公开技术栈。The team project is dated 2023, with proposed configurations recorded separately from physical integration. An independent Webots project and simulation results have not been verified, so Webots is omitted from the confirmed public tech stack.
- DC/DC 上电、纹波和负载瞬态测试需按独立记录确认,本页不将其列为已完成的整车测试。后续 GaN 参考研究不代表原车已制造 GaN PCB,也不使用未经核实的效率数字。DC/DC power-on, ripple and load-transient tests require their own records and are not listed here as completed vehicle tests. Later GaN reference studies do not establish a fabricated GaN board on the vehicle, and no unverified efficiency figure is used.